

12V vs 24V vs 29V Linear Actuators: System Voltage Guide
Compare 12V, 24V, and 29V actuator systems by current, wiring, voltage drop, controller compatibility, motor count, supply architecture, and BOM requirements.

When engineers compare 12V vs 24V vs 29V linear actuators , the most important point is that voltage is a system architecture choice , not a shortcut for predicting force or speed.
The selected DC bus has to match the motor winding, control electronics, power source, connectors, wiring, protection devices, and operating current. A mechanically suitable motion component can still be unusable if its electrical architecture does not match the rest of the system.
For OEM projects, choose voltage by answering four questions:
- What DC bus is already available?
- How much current will the system draw at the required load?
- How long are the cables, and what voltage drop is acceptable?
- Are the motor, controller, supply, connectors, and protection devices all designed for the same voltage class?
12V vs 24V vs 29V comparison table
| Engineering factor | 12V system | 24V system | 29V system |
|---|---|---|---|
| Typical reason to consider it | native 12V battery/vehicle bus, compact low-voltage architecture | lower current than 12V at equal power, common industrial/control ecosystem | matched furniture/motion ecosystem where controller and supply are explicitly designed around 29V |
| Current at equal electrical power | highest of the three | about half of 12V | lower than 24V for the same power |
| Cable voltage-drop sensitivity | highest percentage impact for the same absolute drop | lower percentage impact than 12V | lower again at equal power/current conditions |
| Wire/connector current burden | highest at equal power | lower | lower at equal power |
| Native-bus advantage | useful when the machine already has 12V DC | useful when the machine/control platform already has 24V DC | useful only when the motion ecosystem is intentionally designed around 29V |
| Interchangeability | not interchangeable with higher-voltage devices unless rated | not automatically compatible with 12V or 29V devices | not a drop-in replacement for nominal 24V hardware |
| Supply sizing | check startup, running, stall, and simultaneous loads | same | same |
| Controller requirement | controller must support the motor and 12V bus | controller must support the motor and 24V bus | controller must explicitly support the intended 29V system |
| Best decision basis | total system compatibility | total system compatibility | total system compatibility |
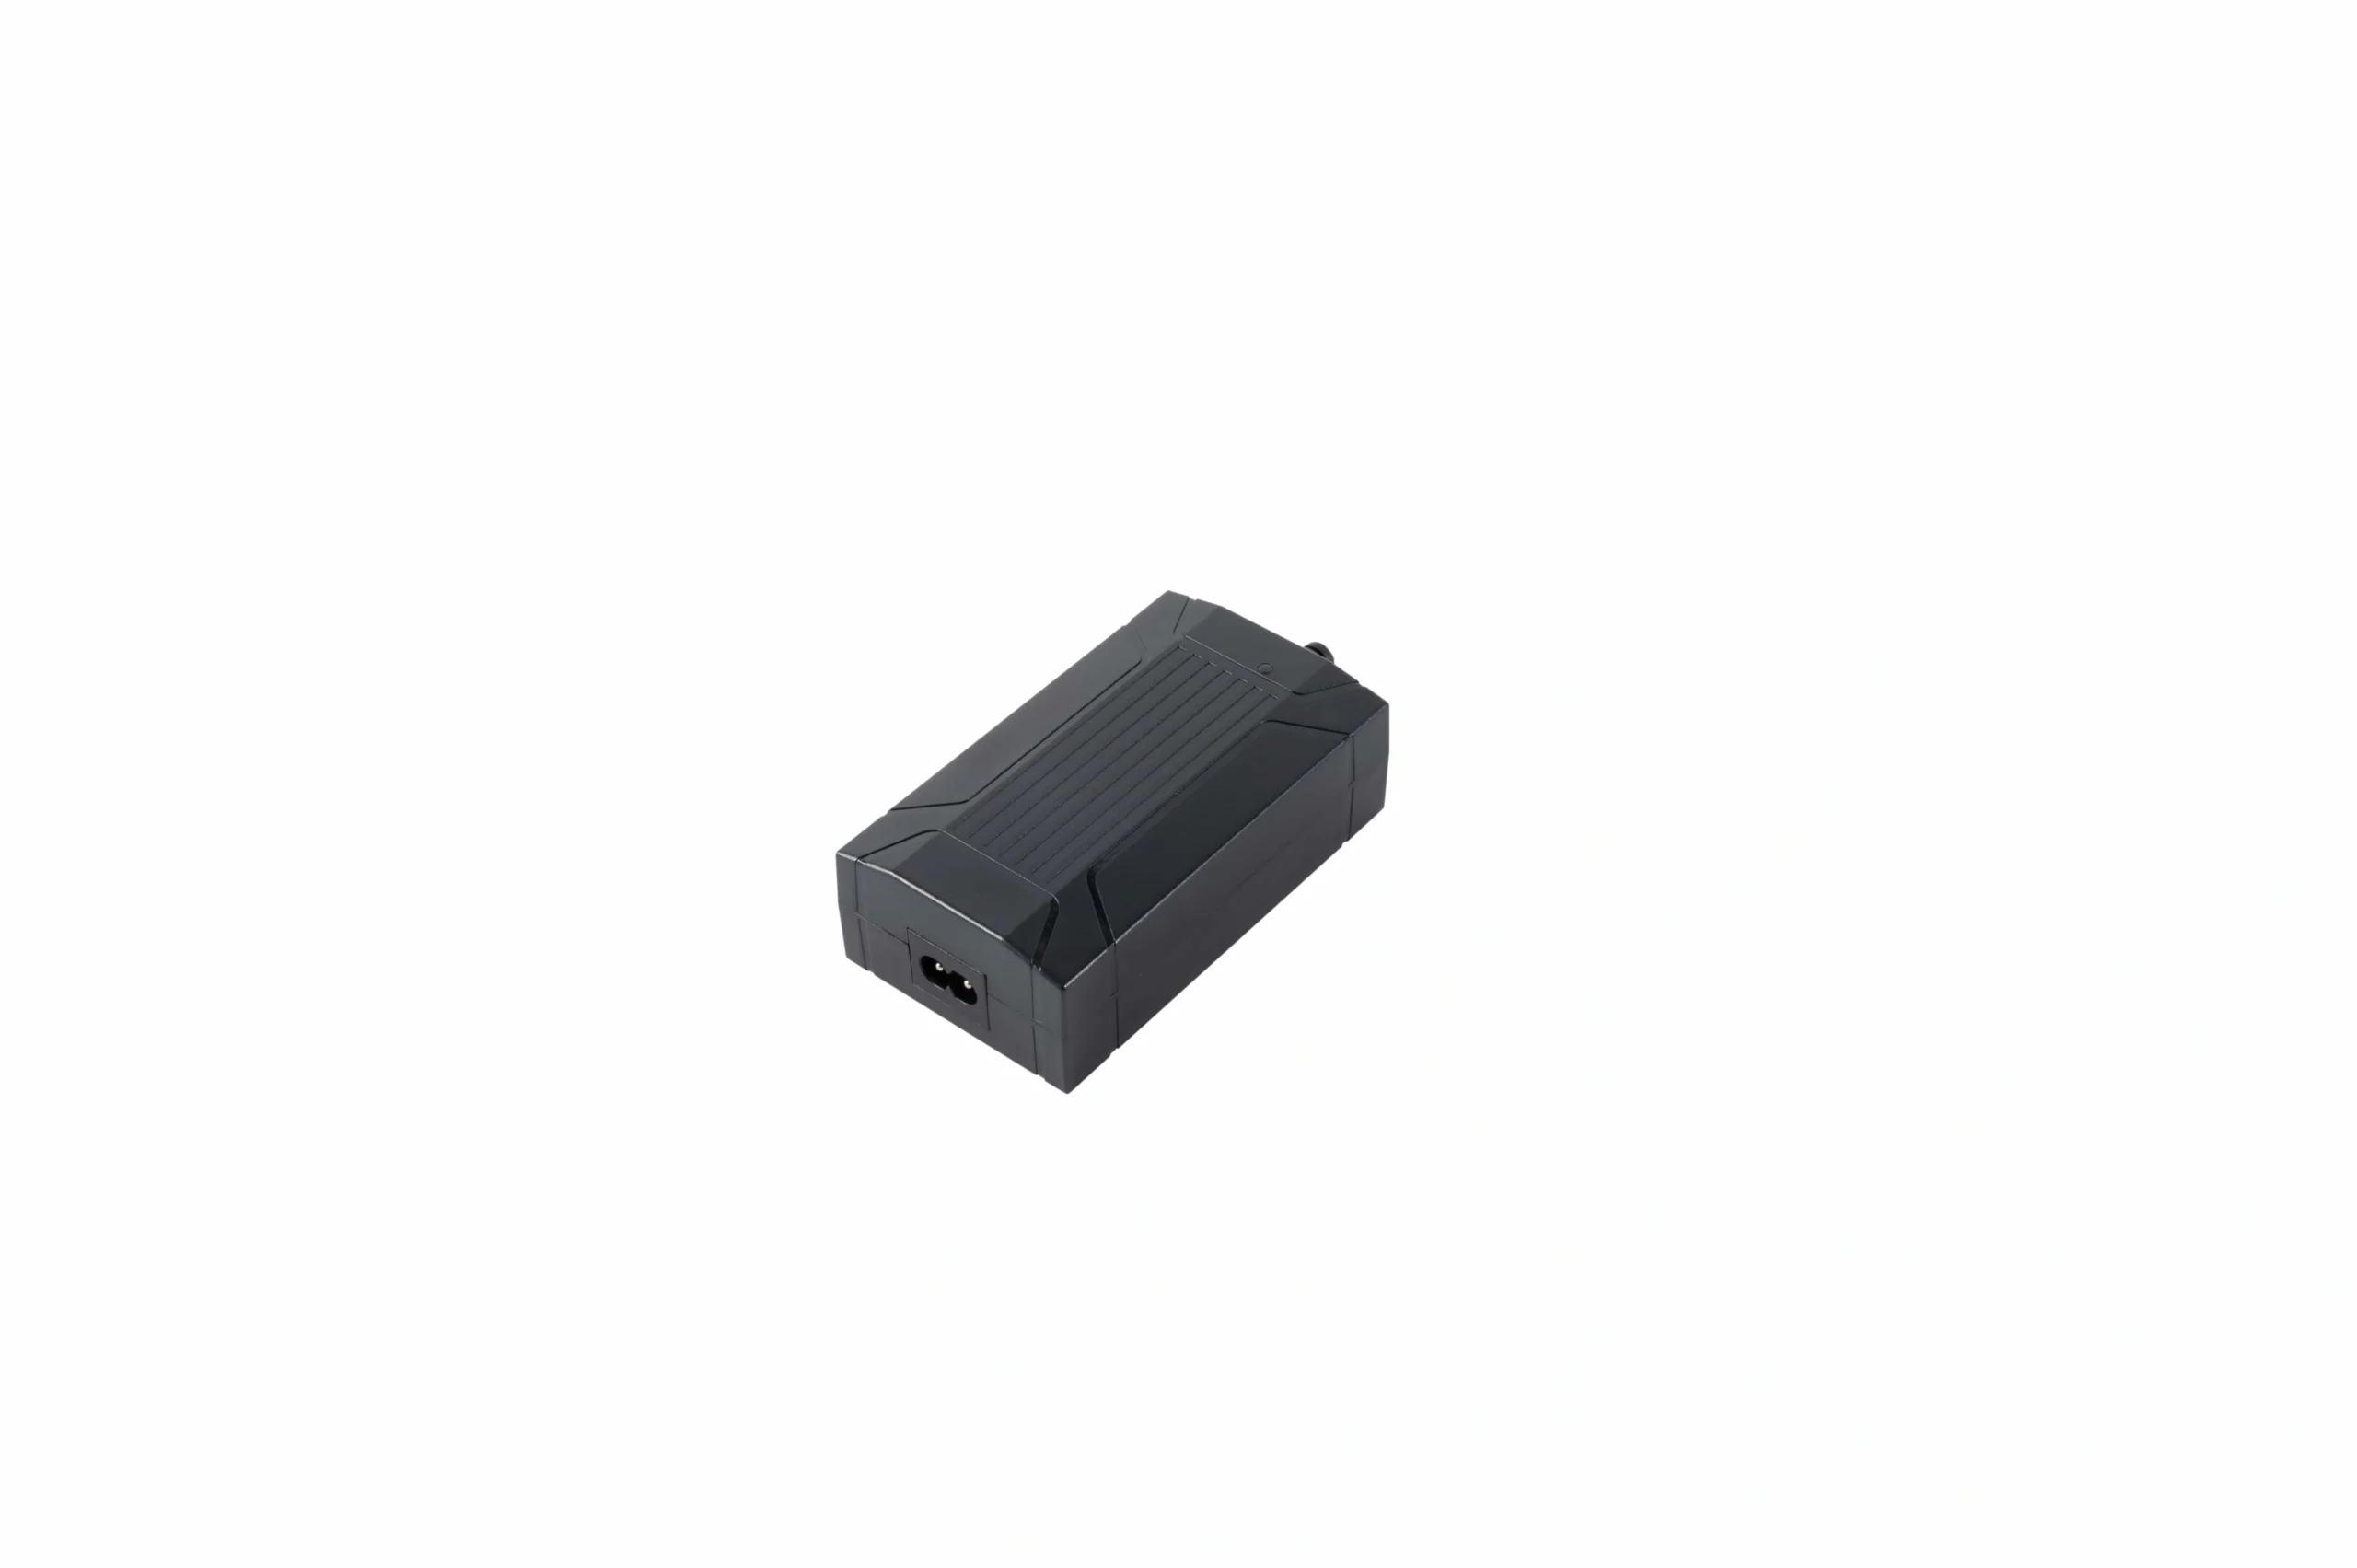
Voltage choice is a system decision: the supply, controller, motor, connectors, and wiring must be specified as one compatible electrical architecture.
The table compares system implications. It does not imply that ServoCylMotion offers product families at every voltage.
Voltage does not determine force or speed by itself
It is tempting to assume that a 24V actuator must be stronger or faster than a 12V version.
That conclusion is not valid without the full design.
Force and speed depend on:
- motor winding;
- motor size;
- gear ratio;
- screw lead;
- transmission efficiency;
- controller current limit;
- supply current capability;
- load point;
- duty cycle;
- mechanical design.
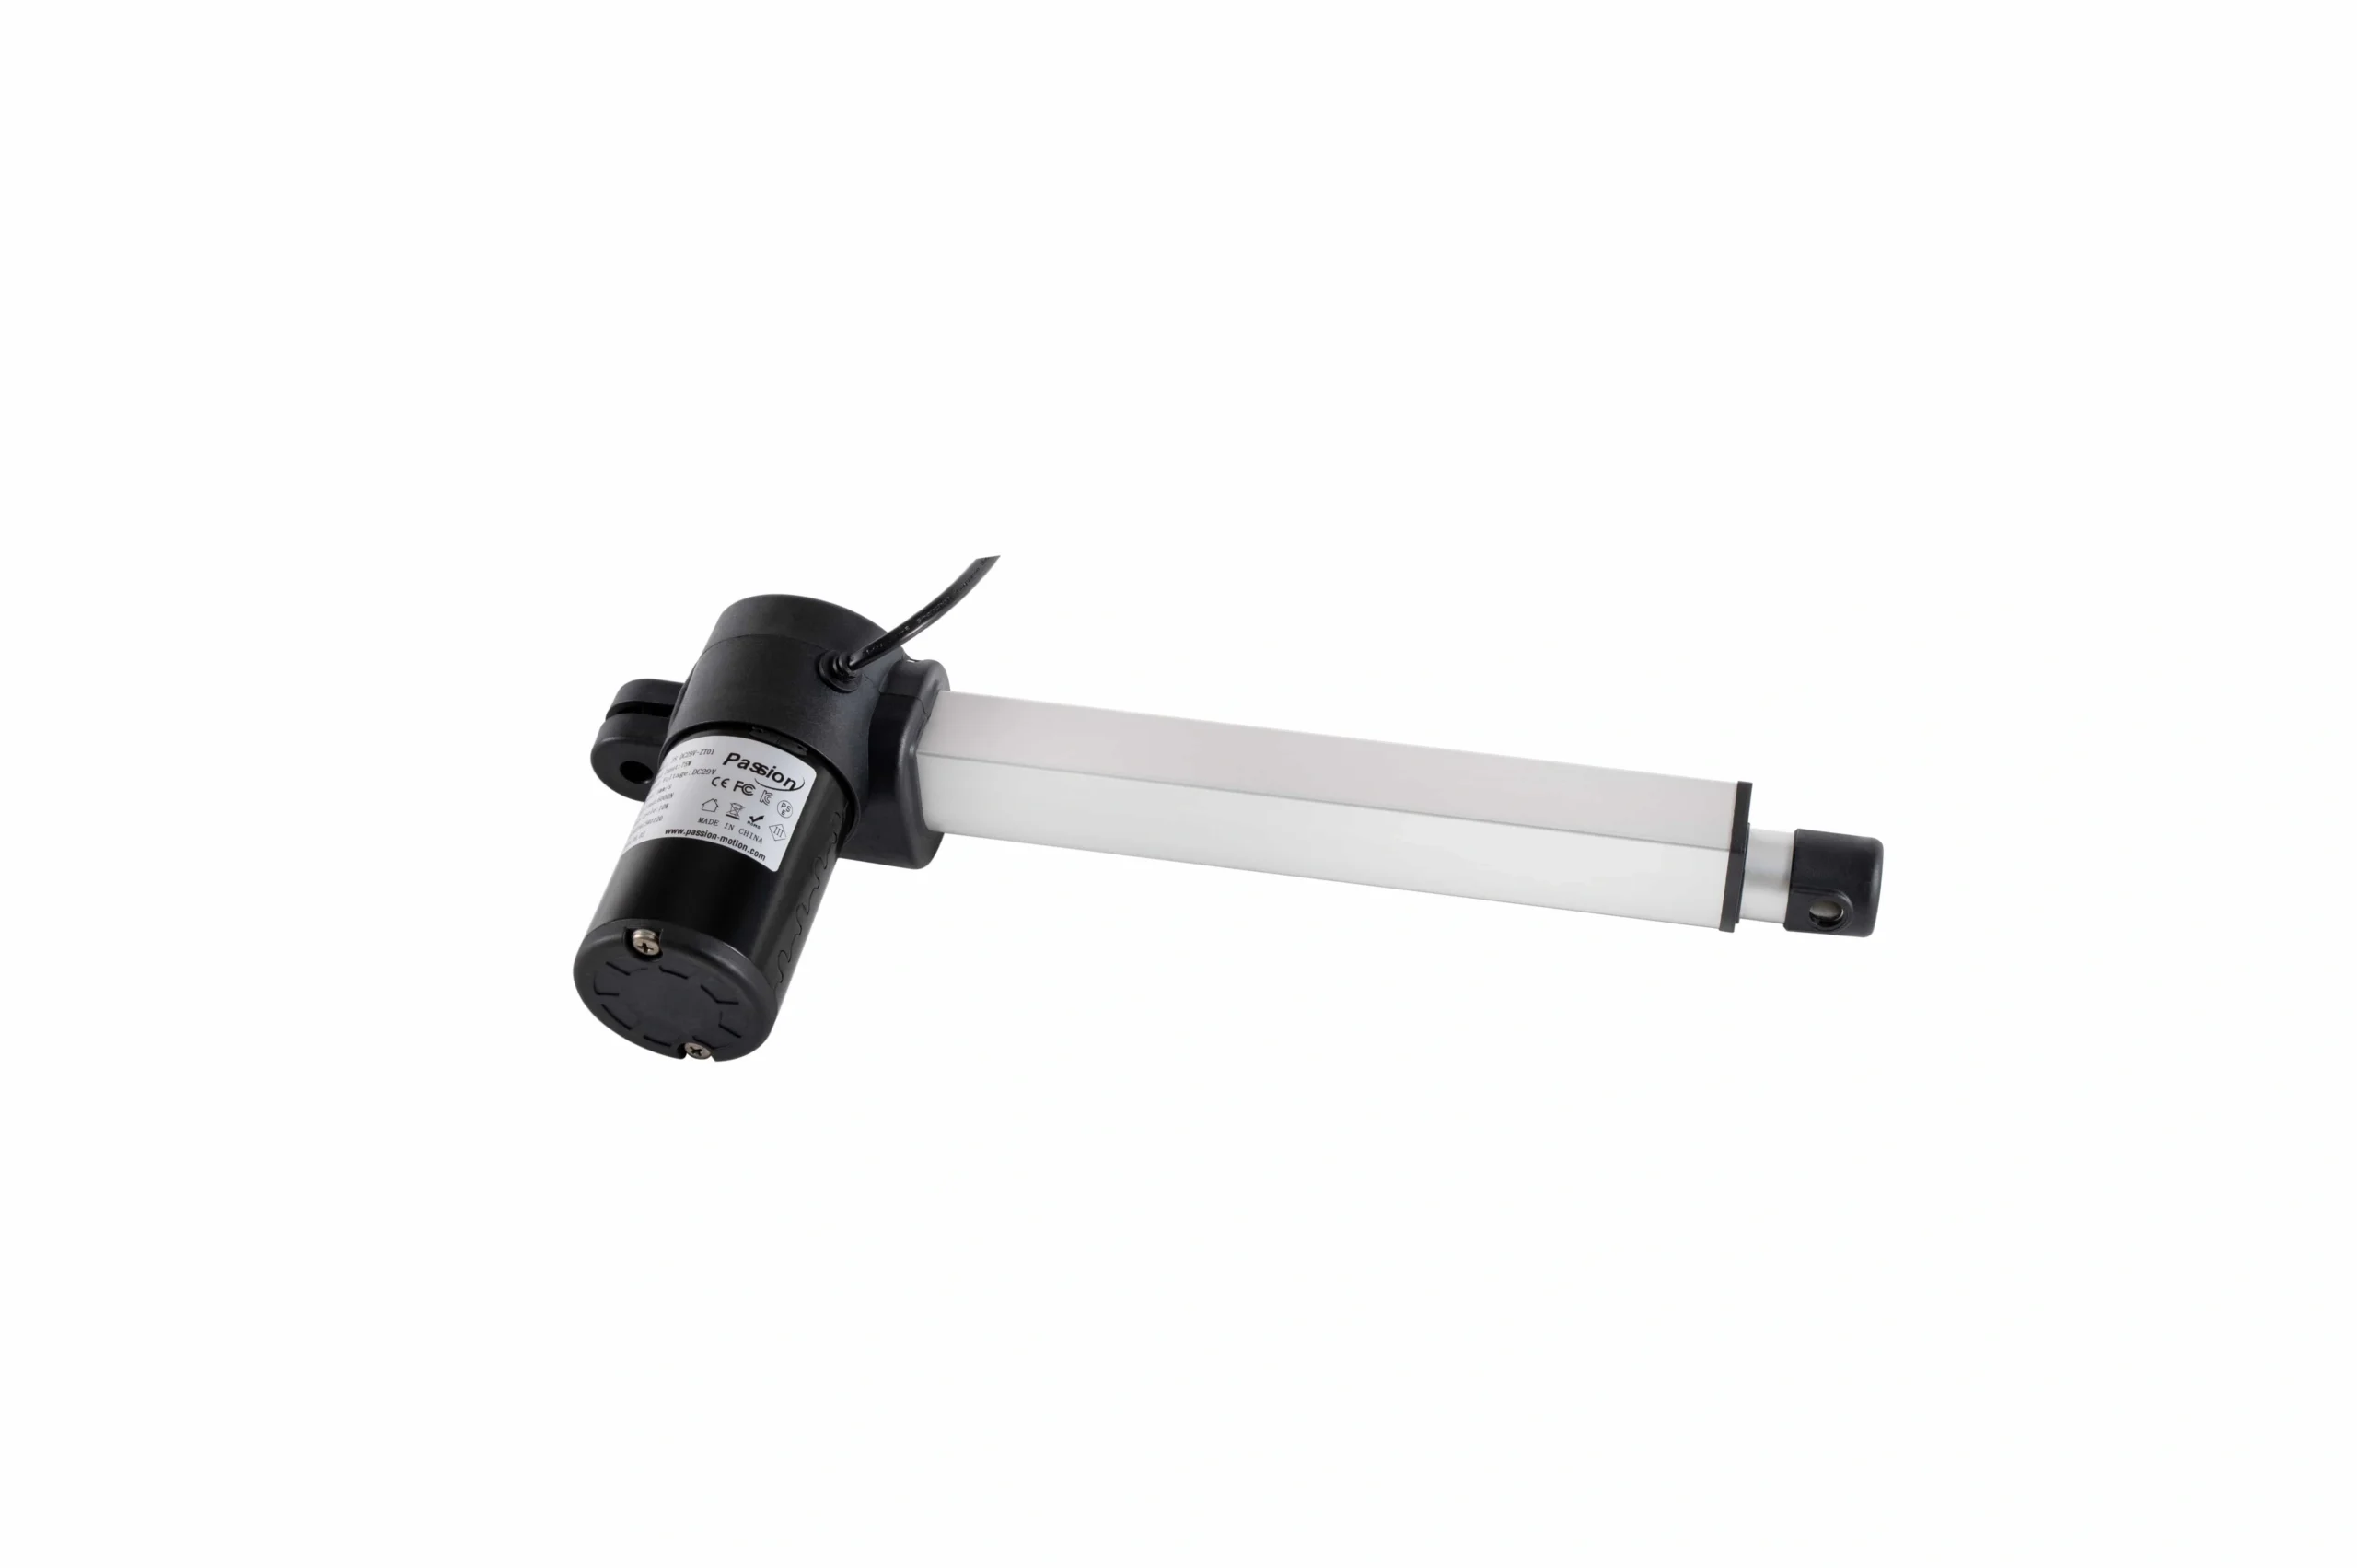
A voltage label alone does not define force or speed; the motor, gearing, controller, load, and rated operating point still govern performance.
A well-designed 12V system can outperform a poorly matched 24V system in a particular application. Likewise, a 29V label alone says nothing about whether a device is suitable for a specific load.
Compare rated force-speed-current data at the intended operating point , not voltage in isolation.
The basic electrical relationship: P = V × I
For DC power:
Power (W) = Voltage (V) × Current (A)
Current (A) = Power (W) / Voltage (V)
This relationship explains one of the main system-level differences between voltage classes.
Worked example: equal 120 W electrical power
If three idealized systems each deliver 120 W of electrical input power:
| Voltage | Ideal current at 120 W |
|---|---|
| 12 V | 10.0 A |
| 24 V | 5.0 A |
| 29 V | 4.14 A |
This is not an actuator performance prediction. It is an electrical comparison only.
Real current depends on motor efficiency, controller losses, load, speed, acceleration, friction, and the actual drive design.
The key takeaway is that for the same electrical power, higher voltage means lower current .
Why current matters to the wiring
Current affects more than the power-supply label.
It affects:
- conductor size;
- connector rating;
- relay or MOSFET current;
- fuse size;
- harness temperature;
- voltage drop;
- contact heating.
Resistive cable loss follows:
Cable loss = I² × R
If current doubles through the same resistance, resistive loss increases by four times.
That is one reason higher-voltage architectures can be attractive for longer cable runs or higher-power systems.
But the conclusion has an important boundary:
You cannot raise voltage merely to reduce current unless the motor, controller, supply, protection, and connected electronics are designed for that voltage.
Voltage drop is a percentage problem
Suppose the wiring loses 1 V between the supply and the controller.
That represents:
- 8.3% of a 12V bus;
- 4.2% of a 24V bus;
- 3.4% of a 29V bus.
The same absolute loss therefore consumes a larger fraction of the available voltage in a lower-voltage system.
Voltage drop can affect:
- motor speed;
- available torque;
- controller undervoltage behavior;
- startup reliability;
- multi-motor synchronization;
- fault resets.
For long cable runs, verify:
- wire gauge;
- total loop length;
- maximum current;
- connector resistance;
- expected voltage at the controller under load.
Startup and stall current can dominate supply sizing
The current printed beside a nominal operating condition may not be the worst case.
A DC motor can draw substantially more current during:
- startup;
- hard acceleration;
- high-load movement;
- stall;
- obstruction;
- direction reversal.
A supply that works during no-load testing may sag or enter protection when the real mechanism starts under load.
For each motor channel, freeze:
- no-load current;
- expected loaded current;
- startup/peak current;
- stall current or controller current limit;
- permitted duration;
- duty cycle.
For multiple motors, also define which axes are allowed to start or move simultaneously.
Multi-motor systems need a total current budget
A two-motor system is not sized by simply checking one motor twice.
The controller may:
- start both motors together;
- start them sequentially;
- limit each channel;
- limit total current;
- stop both if one faults;
- compensate for position mismatch.
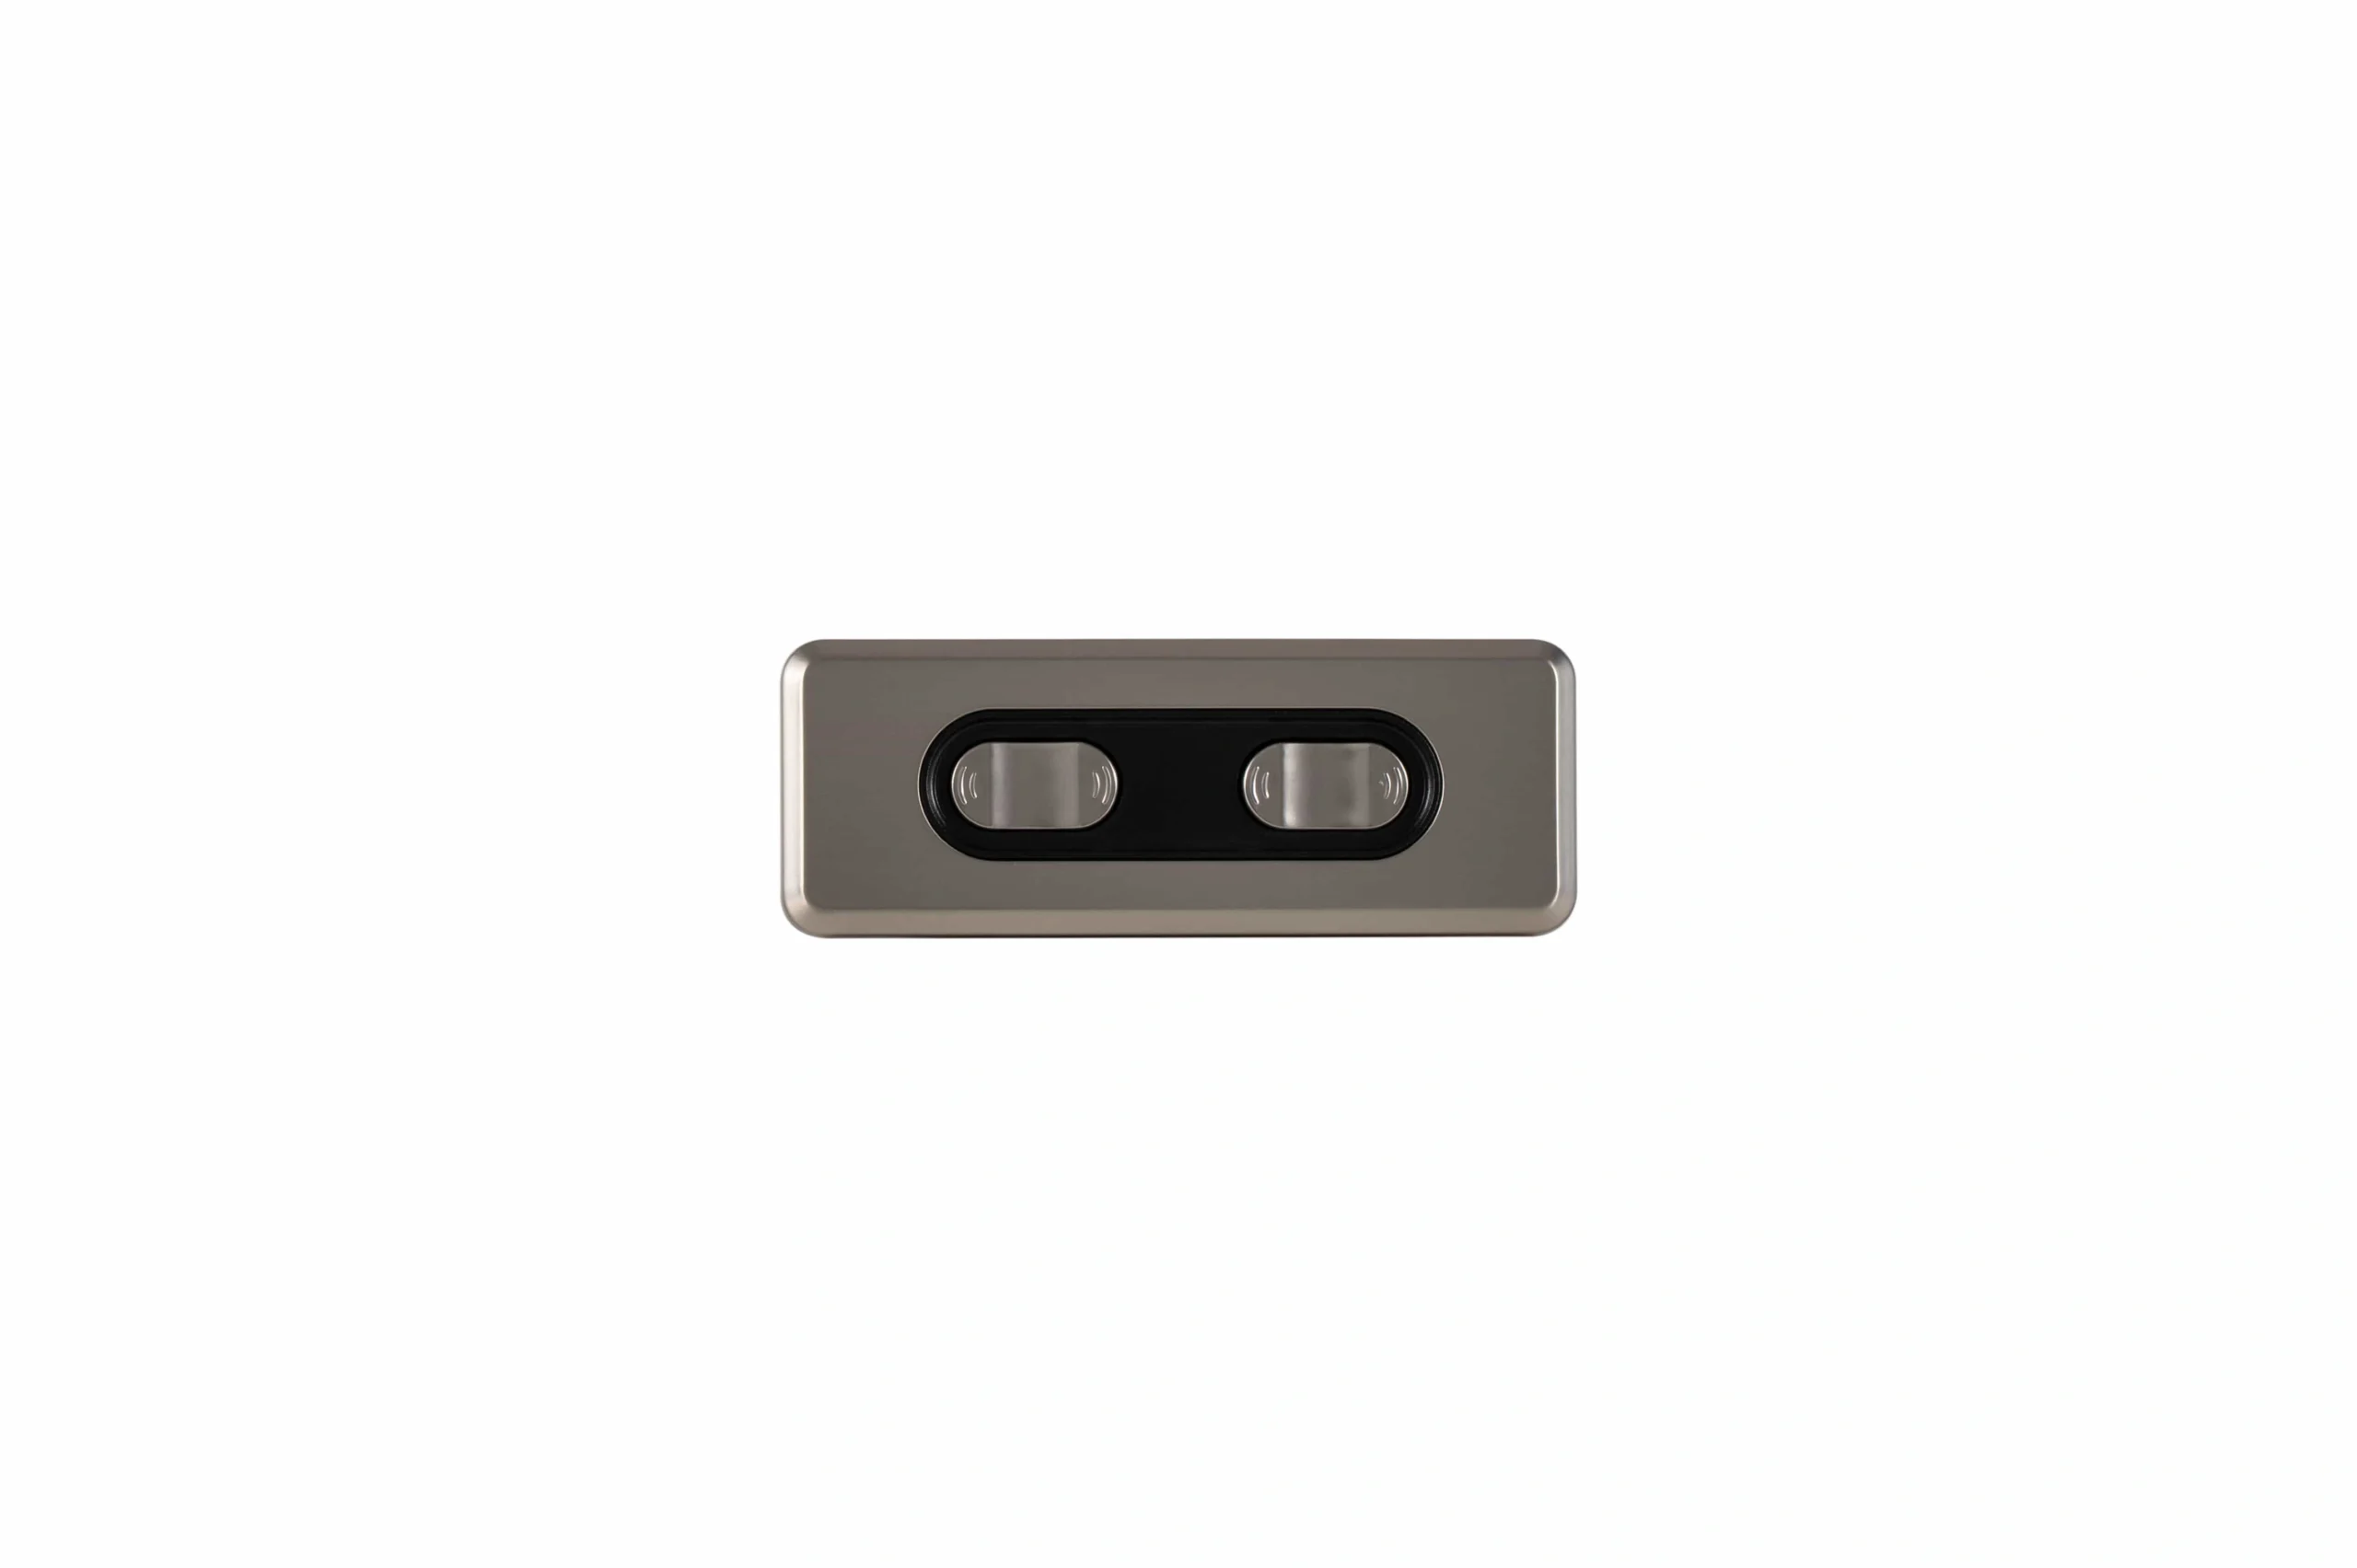
Multi-motor systems must budget simultaneous current and confirm controller channel ratings, connector limits, and supply capacity.
The supply and harness should therefore be checked against the worst permitted operating state , including simultaneous startup if the controller allows it.
A useful system current table is:
| Item | Running current | Startup/peak current | Simultaneous? |
|---|---|---|---|
| Motor 1 | project value | project value | yes/no |
| Motor 2 | project value | project value | yes/no |
| Controller electronics | project value | project value | always |
| Accessories | project value | project value | depends |
| Design margin | project rule | — | — |
Do not populate these values from a neighboring model. Use the actual project data.
Why 12V can make sense
A 12V architecture can be practical when the machine already has a native 12V source, such as:
- vehicle electrical systems;
- battery-powered equipment;
- compact mobile devices;
- legacy low-voltage platforms.
The advantage is often architectural simplicity: fewer conversion stages and direct use of the native bus.
The tradeoff is higher current for a given power level, which can increase:
- cable size;
- connector current requirements;
- voltage-drop sensitivity;
- fuse/current-limit requirements.
For a new design with no native bus constraint, compare the total wiring and control architecture before committing.
Why 24V can make sense
24V is widely used in industrial control environments, which can simplify integration when the rest of the machine already uses a compatible 24V DC bus.
At equal electrical power compared with 12V, current is lower.
That can help with:
- long harnesses;
- connector loading;
- voltage drop;
- distribution losses.
However, a 24V controller cannot be assumed compatible with every 24V motor, and a nominal 24V motor cannot automatically accept a different supply voltage.
The complete input range and current requirements still have to be verified.
Why 29V appears in actuator ecosystems
29V often appears in furniture and low-voltage motion ecosystems that use a dedicated AC/DC adapter, control box, handset, and one or more motors as a matched system.
The important word is matched .
A 29V supply should not be treated as a universal replacement for a nominal 24V supply.
Verify:
- controller input range;
- motor rated voltage;
- protection thresholds;
- connector/pinout;
- feedback interface;
- supply current;
- firmware/configuration;
- allowed accessories.
ServoCylMotion has a documented 29V accessory ecosystem at the project level, but model-specific combinations still need compatibility verification.
Use the system compatibility resource before freezing a controller-supply-motor combination.
Do not overvoltage a nominal device by assumption
A common mistake is reasoning:
29V is close to 24V, so it should be fine.
That is not an engineering specification.
A device may have:
- a narrow input range;
- controller overvoltage protection;
- motor heating limits;
- speed limits;
- relay/MOSFET voltage limits;
- accessory limits.
Only the documented input range or approved system combination establishes compatibility.
Likewise, running a motor below its intended voltage can change speed, available torque, current behavior, and controller response.
Native bus vs dedicated adapter architecture
Voltage selection often follows one of two architectures.
Native DC bus
The actuator system uses the machine's existing battery or DC supply.
Advantages:
- fewer conversion stages;
- simpler power distribution;
- shared protection architecture.
Questions:
- is voltage stable across all operating conditions?
- what happens during engine charging or battery discharge?
- can the bus supply startup current?
- is noise/transient protection adequate?
Dedicated AC/DC adapter
The motion system has its own supply.
Advantages:
- controlled output voltage;
- easier subsystem isolation;
- simpler qualification of a matched ecosystem.
Questions:
- is current capacity sufficient?
- what protection modes exist?
- what connector is used?
- does the adapter recover correctly after overload?
- is the regional AC cord separate from the DC system definition?
Regional plug questions belong in the separate plug-standard guide rather than this voltage comparison.
Freeze the BOM as a compatibility matrix
Before release, create a compatibility table.
| BOM item | Required field |
|---|---|
| Motor / motion component | rated voltage range, running/peak current, feedback |
| Controller | input voltage range, channel current, total current, feedback type |
| DC supply | output voltage, continuous/peak current, protection behavior |
| Harness | wire gauge, length, connector, pinout |
| AC input cord | regional plug format, current/voltage rating |
| Fuse/protection | rating and coordination |
| Firmware/configuration | approved revision |
| Multi-motor logic | simultaneous operation and current limits |
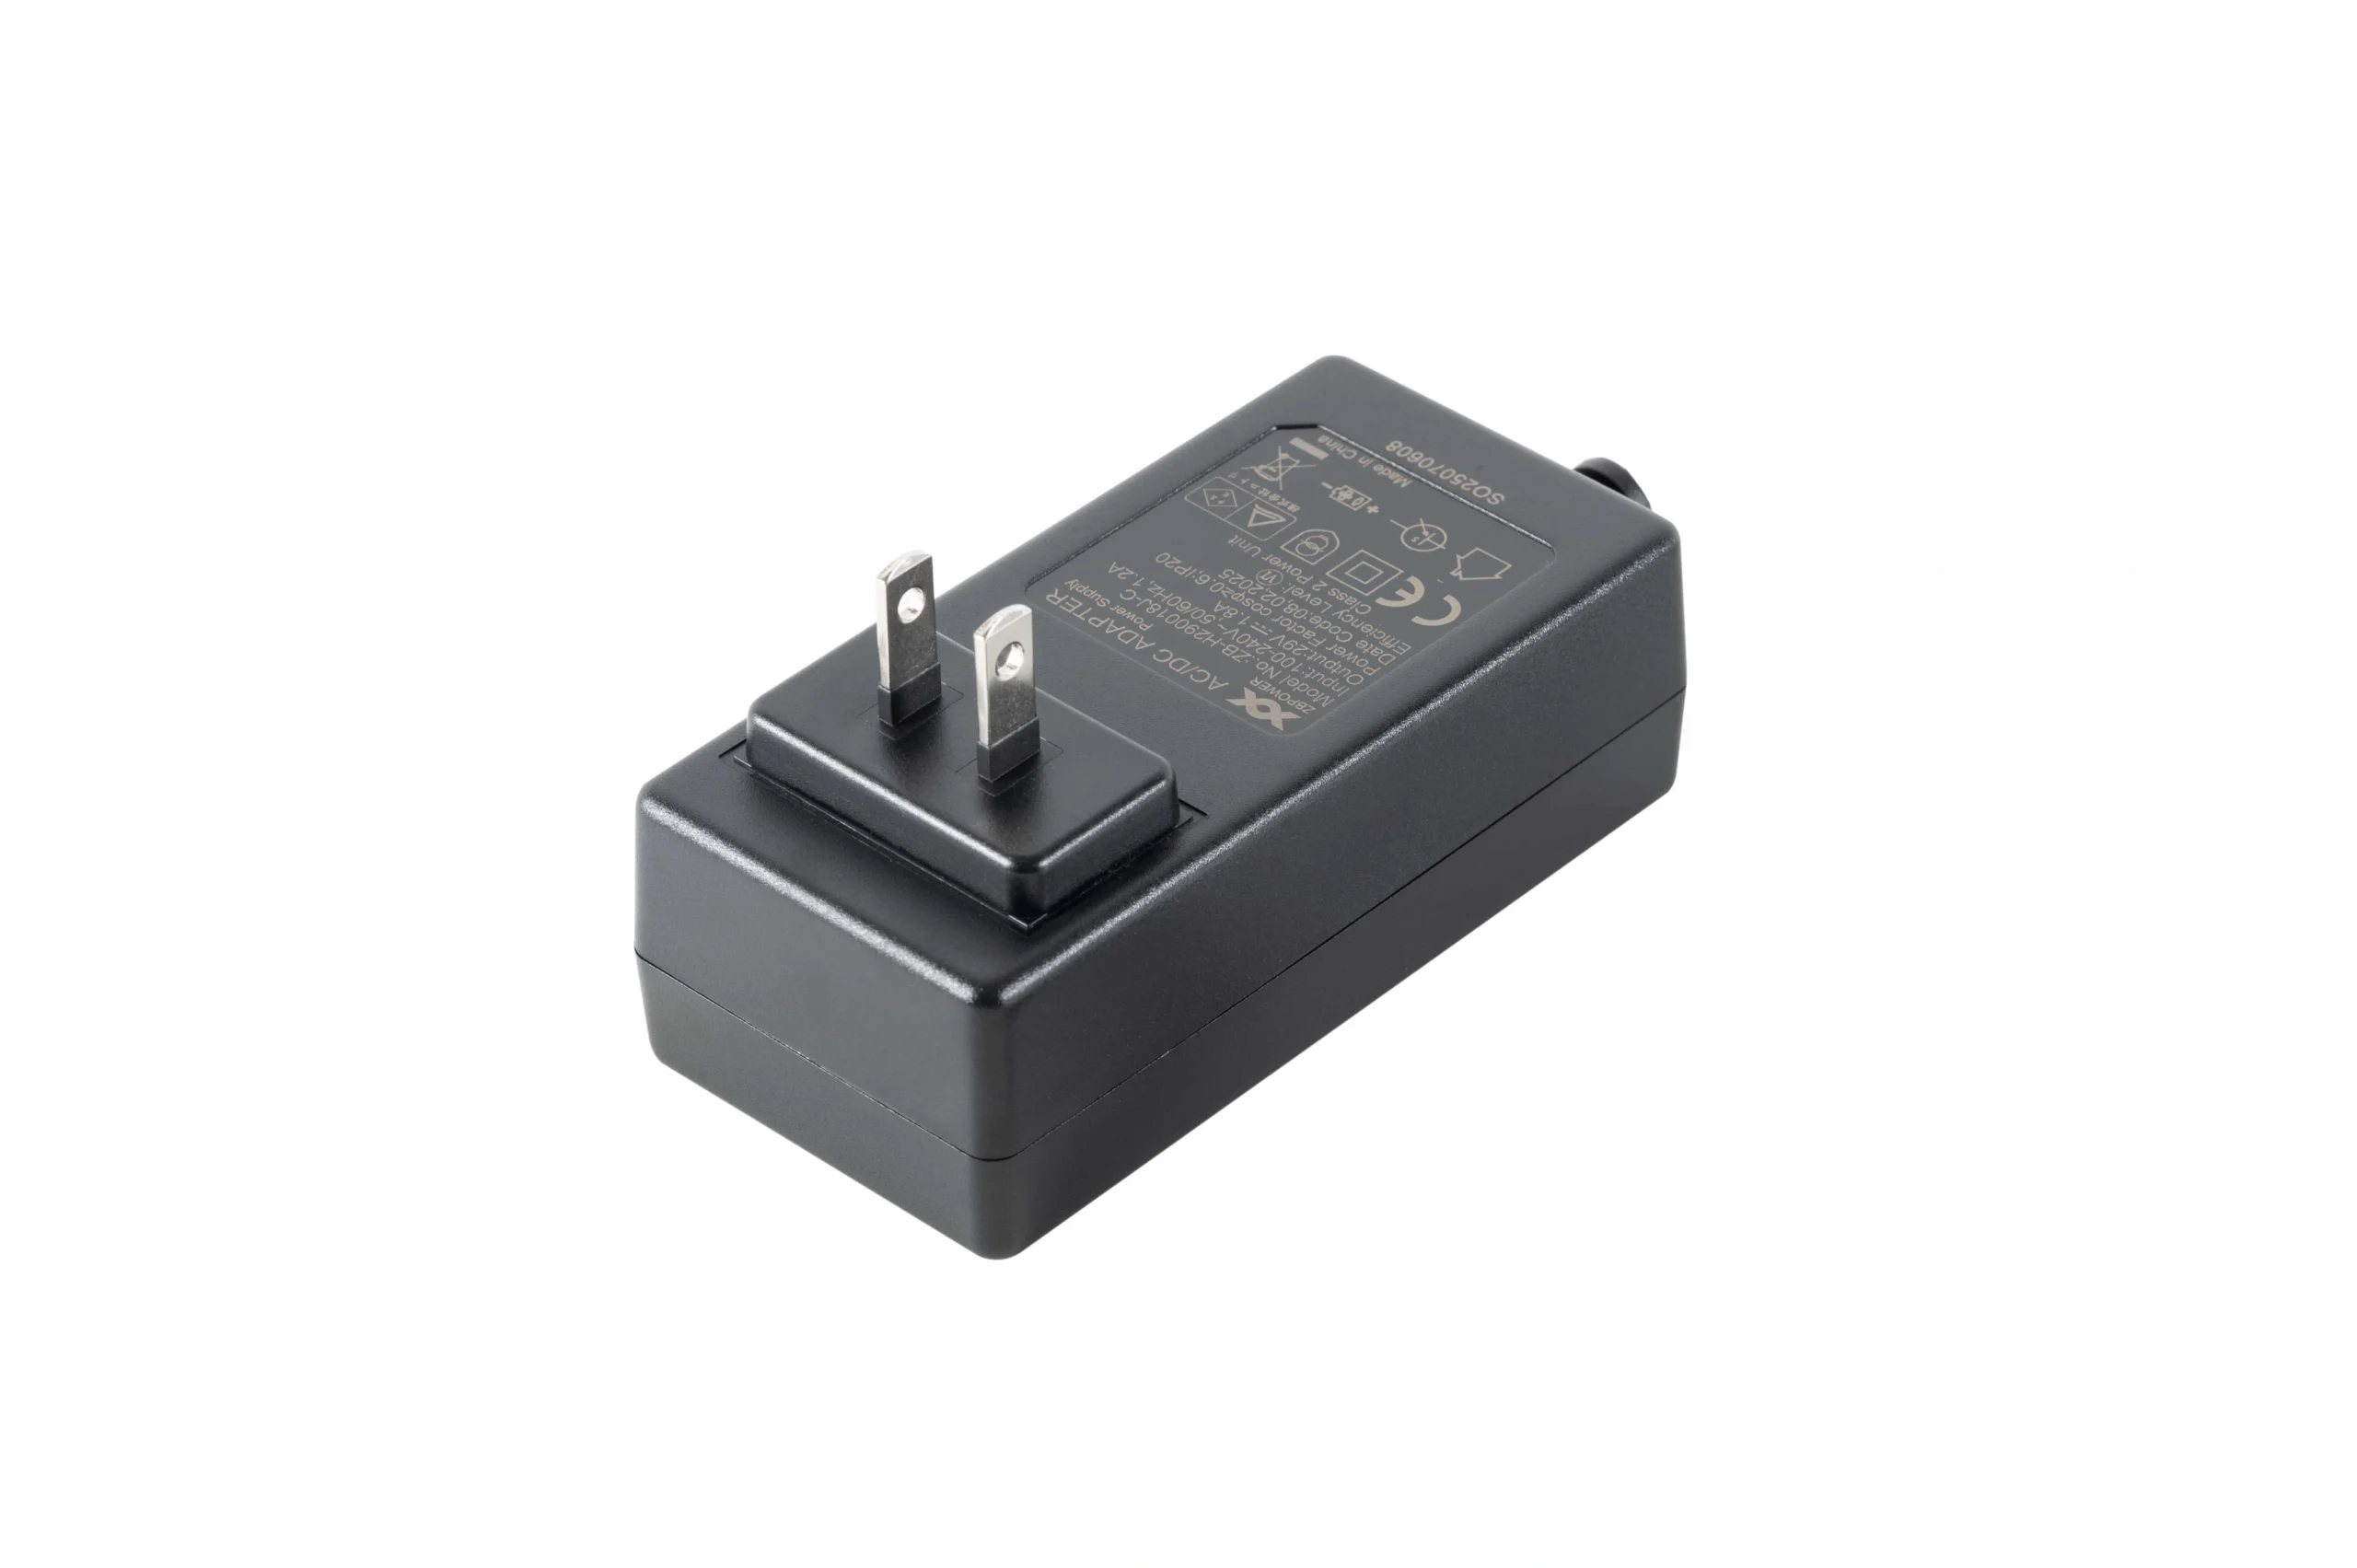
Before freezing a supply, verify output range, current capacity, connector/pinout, protection behavior, and compatibility with the control system.
A supply that physically plugs into a controller is not automatically electrically compatible.
For documented ServoCylMotion supply options, use the 29V power-supply family only after the required output and compatibility conditions are known.
Validation checklist
Before production release, test the full electrical configuration.
Voltage
- no-load supply voltage;
- voltage under maximum load;
- low-line and high-line input conditions;
- controller undervoltage/overvoltage behavior.
Current
- startup current;
- loaded running current;
- simultaneous motor current;
- stall/obstruction behavior;
- current-limit response.
Wiring
- voltage at the farthest motor;
- connector temperature;
- cable temperature;
- voltage drop;
- ground-return drop.
Controls
- direction reversal;
- end limits;
- feedback;
- multi-axis synchronization;
- fault recovery;
- reset behavior.
Thermal
- representative duty cycle;
- supply temperature;
- controller temperature;
- connector/harness temperature.
Record the exact supply, controller, motor, harness, firmware, and parameter revision used in the validation.
Quick selection rule
Choose 12V when a compatible native 12V bus and system architecture make it the best fit.
Choose 24V when the machine is built around a compatible 24V control/power ecosystem and the reduced current helps the wiring architecture.
Choose 29V only when the motion system is explicitly designed and validated around a 29V-compatible controller, motors, supply, and accessories.
In every case, choose the system, not the number .
FAQs
Does 24V automatically make an actuator faster than 12V?
No. Voltage alone does not determine speed. Motor winding, gearing, controller behavior, current limit, load, and mechanical design determine the rated performance.
Why can 24V use less current than 12V?
At equal electrical power, current is inversely proportional to voltage: I = P / V. A 120 W ideal load draws 10 A at 12V but 5 A at 24V.
Can a 29V supply power a nominal 24V device?
Only if the device and controller documentation explicitly allow that input range or the combination is validated as an approved system. Do not assume compatibility from the voltage numbers being close.
Why does wire gauge matter more at lower voltage?
For equal power, lower voltage requires higher current. Higher current increases voltage drop and I²R heating for the same cable resistance.
How do I size the supply for two motors?
Use the worst permitted simultaneous condition, including startup/peak current, controller consumption, accessories, and a documented engineering margin. The detailed calculation belongs in the 29V supply-sizing guide.
What should be frozen before production?
Freeze the motor/controller/supply voltage ranges, current limits, connector/pinout, wire gauge and length, protection devices, multi-motor behavior, firmware/configuration, and validated test state.
