
電動シリンダーは通常、リニアアクチュエータの一種であり、両者は電力から直線運動を生み出します。エンジニアリングとしての比較は狭義です。プログラム可能な機械運動用に構成されたサーボ駆動スクリューシリンダーと、モーター、ギアボックス、スクリュー、リミット、オプションのフィードバックを組み合わせたDCロッドまたはスライダーユニットの選択です。
完全なエンジニアリングフレームワークについては、こちらをご覧ください 電動シリンダーエンジニアリング選択ガイド.
完全な運転点、必要な制御、電源喪失後の挙動、負荷ガイダンス、アクチュエータ周辺に必要な部品を確認することで選択します。ファミリーネームだけでは、力、速度、精度、デューティサイクル、またはコストは決まりません。
重要なポイント
- 用語が重複します。アクチュエータは最も広いカテゴリーであり、リニアアクチュエータは直線運動を生成し、シリンダースタイルの電動ユニットはその一例です。
- サーボスクリューシリンダーは、プログラム可能な位置、運動プロファイル、協調軸、およびプロセスモニタリングに対して強力な候補です。
- パッケージDCユニットは、正確な定格と制御がメカニズムに適合する場合、シンプルな展開/収縮や間欠的な位置決めに適しています。
- どちらのアーキテクチャも、連続のデューティ、荷重保持、側面荷重耐性、または測定されたプロセス力を保証しません。
- 定義された荷重速度ストロークサイクルポイントと完全な制御、取り付け、安全システムを比較してください。
なぜ製品名が重複するのか
業界名は記述的であり、普遍的な分類標準ではありません。ジョイス/デイトンは、電動シリンダーを電気エネルギーを直線運動に変換するアクチュエータの一種と説明し、トロマティックはロッドスタイル、ロッドレス、一体型サーボ、および外部モーター設計をより広いリニアモーション範囲内にグループ化しています。両方の製造元の情報源は参考文献に記載されています。
この比較のために、両方の側は次のように意味します:
| 比較側 | 代表的なアーキテクチャ | 典型的な決定文脈 |
|---|---|---|
| サーボスクリューシリンダー | サーボモーターとドライブ、ボールまたはローラスクリュー、スラストロッド、ベアリング、フィードバック、インラインまたはパラレルモーター配置のいずれか | プログラム可能な産業モーション、繰り返し可能な軌道、協調軸、または力に関連するプロセス |
| パッケージ化されたDCロッドまたはスライダーユニット | DCモーター、ギアボックス、リード/アクメまたはボールスクリュー、ロッドまたはカート、エンドリミット、およびモデル特有のフィードバック/制御オプション | エンドポイントモーション、間欠調整、リフティング、オープニング、または簡単なコントロールでのポジショニング |
これは代表的な実装であり、厳密な定義ではありません。コンパクトロッドユニットは位置フィードバックとオンボード制御を含む場合があります。サーボシリンダーは統合モーター、インライン外部モーター、またはベルトまたはギアボックスを使用したフォールバックモーターを使用できます。

DG52の図面は、パラレルモーター配置のスクリューシリンダーを示しています。製品名のみではその稼働範囲を定義することはできません。
ラベルの背後にあるアーキテクチャを比較する
サーボスクリューシリンダーでは、サーボドライブがエンコーダーまたはリゾルバーフィードバックからモーターの動作を調整します。モーターはスクリューを直接回転させるか、カップリング、ベルト、またはギアボックスを介して回転させます。ナットは回転をスラストロッドの軸方向移動に変換します。ドライブとコントローラーは位置、速度、加速度、およびトルクに関連する制限を命令できます。
パッケージ化されたDCユニットでは、ハウジングには通常モーター、減速機、スクリュー、ナット、および出力ロッドまたはカートが含まれます。基本バージョンは極性を変更することで逆転でき、エンドリミットで停止します。他のモデルではポテンショメーター、ホールフィードバック、エンコーダー、内部コントローラー、またはネットワークインターフェースを追加する場合があります。したがって、「パッケージ化されたDC」は、正確なモデルがそう言わない限り、「オープンループ」を意味しません。
Tolomaticの統合と従来の比較は、参照に記載されており、システムの境界が重要である理由も示しています。外部モーターマウントを取り外すことでカップリングやアライメント作業が減少する可能性がありますが、軸には依然として互換性のあるドライブパラメータ、フィードバック、ケーブル、コントローラーロジック、および調整が必要です。
| 設計の質問 | サーボスクリューシリンダー | パッケージ化されたDCユニット |
|---|---|---|
| モーターとドライブ | サーボモーターと互換性のあるドライブ;モーターは統合されるか、外部に取り付けられます | モーターと減速機は通常製品内部にあります;スイッチングまたはコントローラーは組み込まれていない限り外部に残ります |
| 運動変換 | 通常はボールまたはローラーねじ;正確なねじとリードが性能を決定します | モデルと価格/性能ターゲットに応じてリード/アクメねじまたはボールねじ |
| 位置フィードバック | 通常はサーボループの一部であり、ドライブ固有の互換性があります | エンドリミットは標準のものかもしれません;連続位置フィードバックはオプションまたはモデル特有です |
| 中間位置 | 正しくコミッションされた場合、プログラムされた位置と軌道に適しています | 適切なフィードバックとコントローラーがあれば可能です |
| 機械パッケージング | モーター、ドライブ、ギヤボックス、取り付けアーキテクチャの選択肢が増えます | コンパクトな自己完結型パッケージは基本的な設置を簡素化することができます |
| サービス境界 | モーター、ドライブ、フィードバック、ブレーキ、ねじ、ベルト/カップリング、機械は別々のサービス項目である場合があります | 完全ユニットの交換は一般的です;内部修理オプションは製品によって異なります |
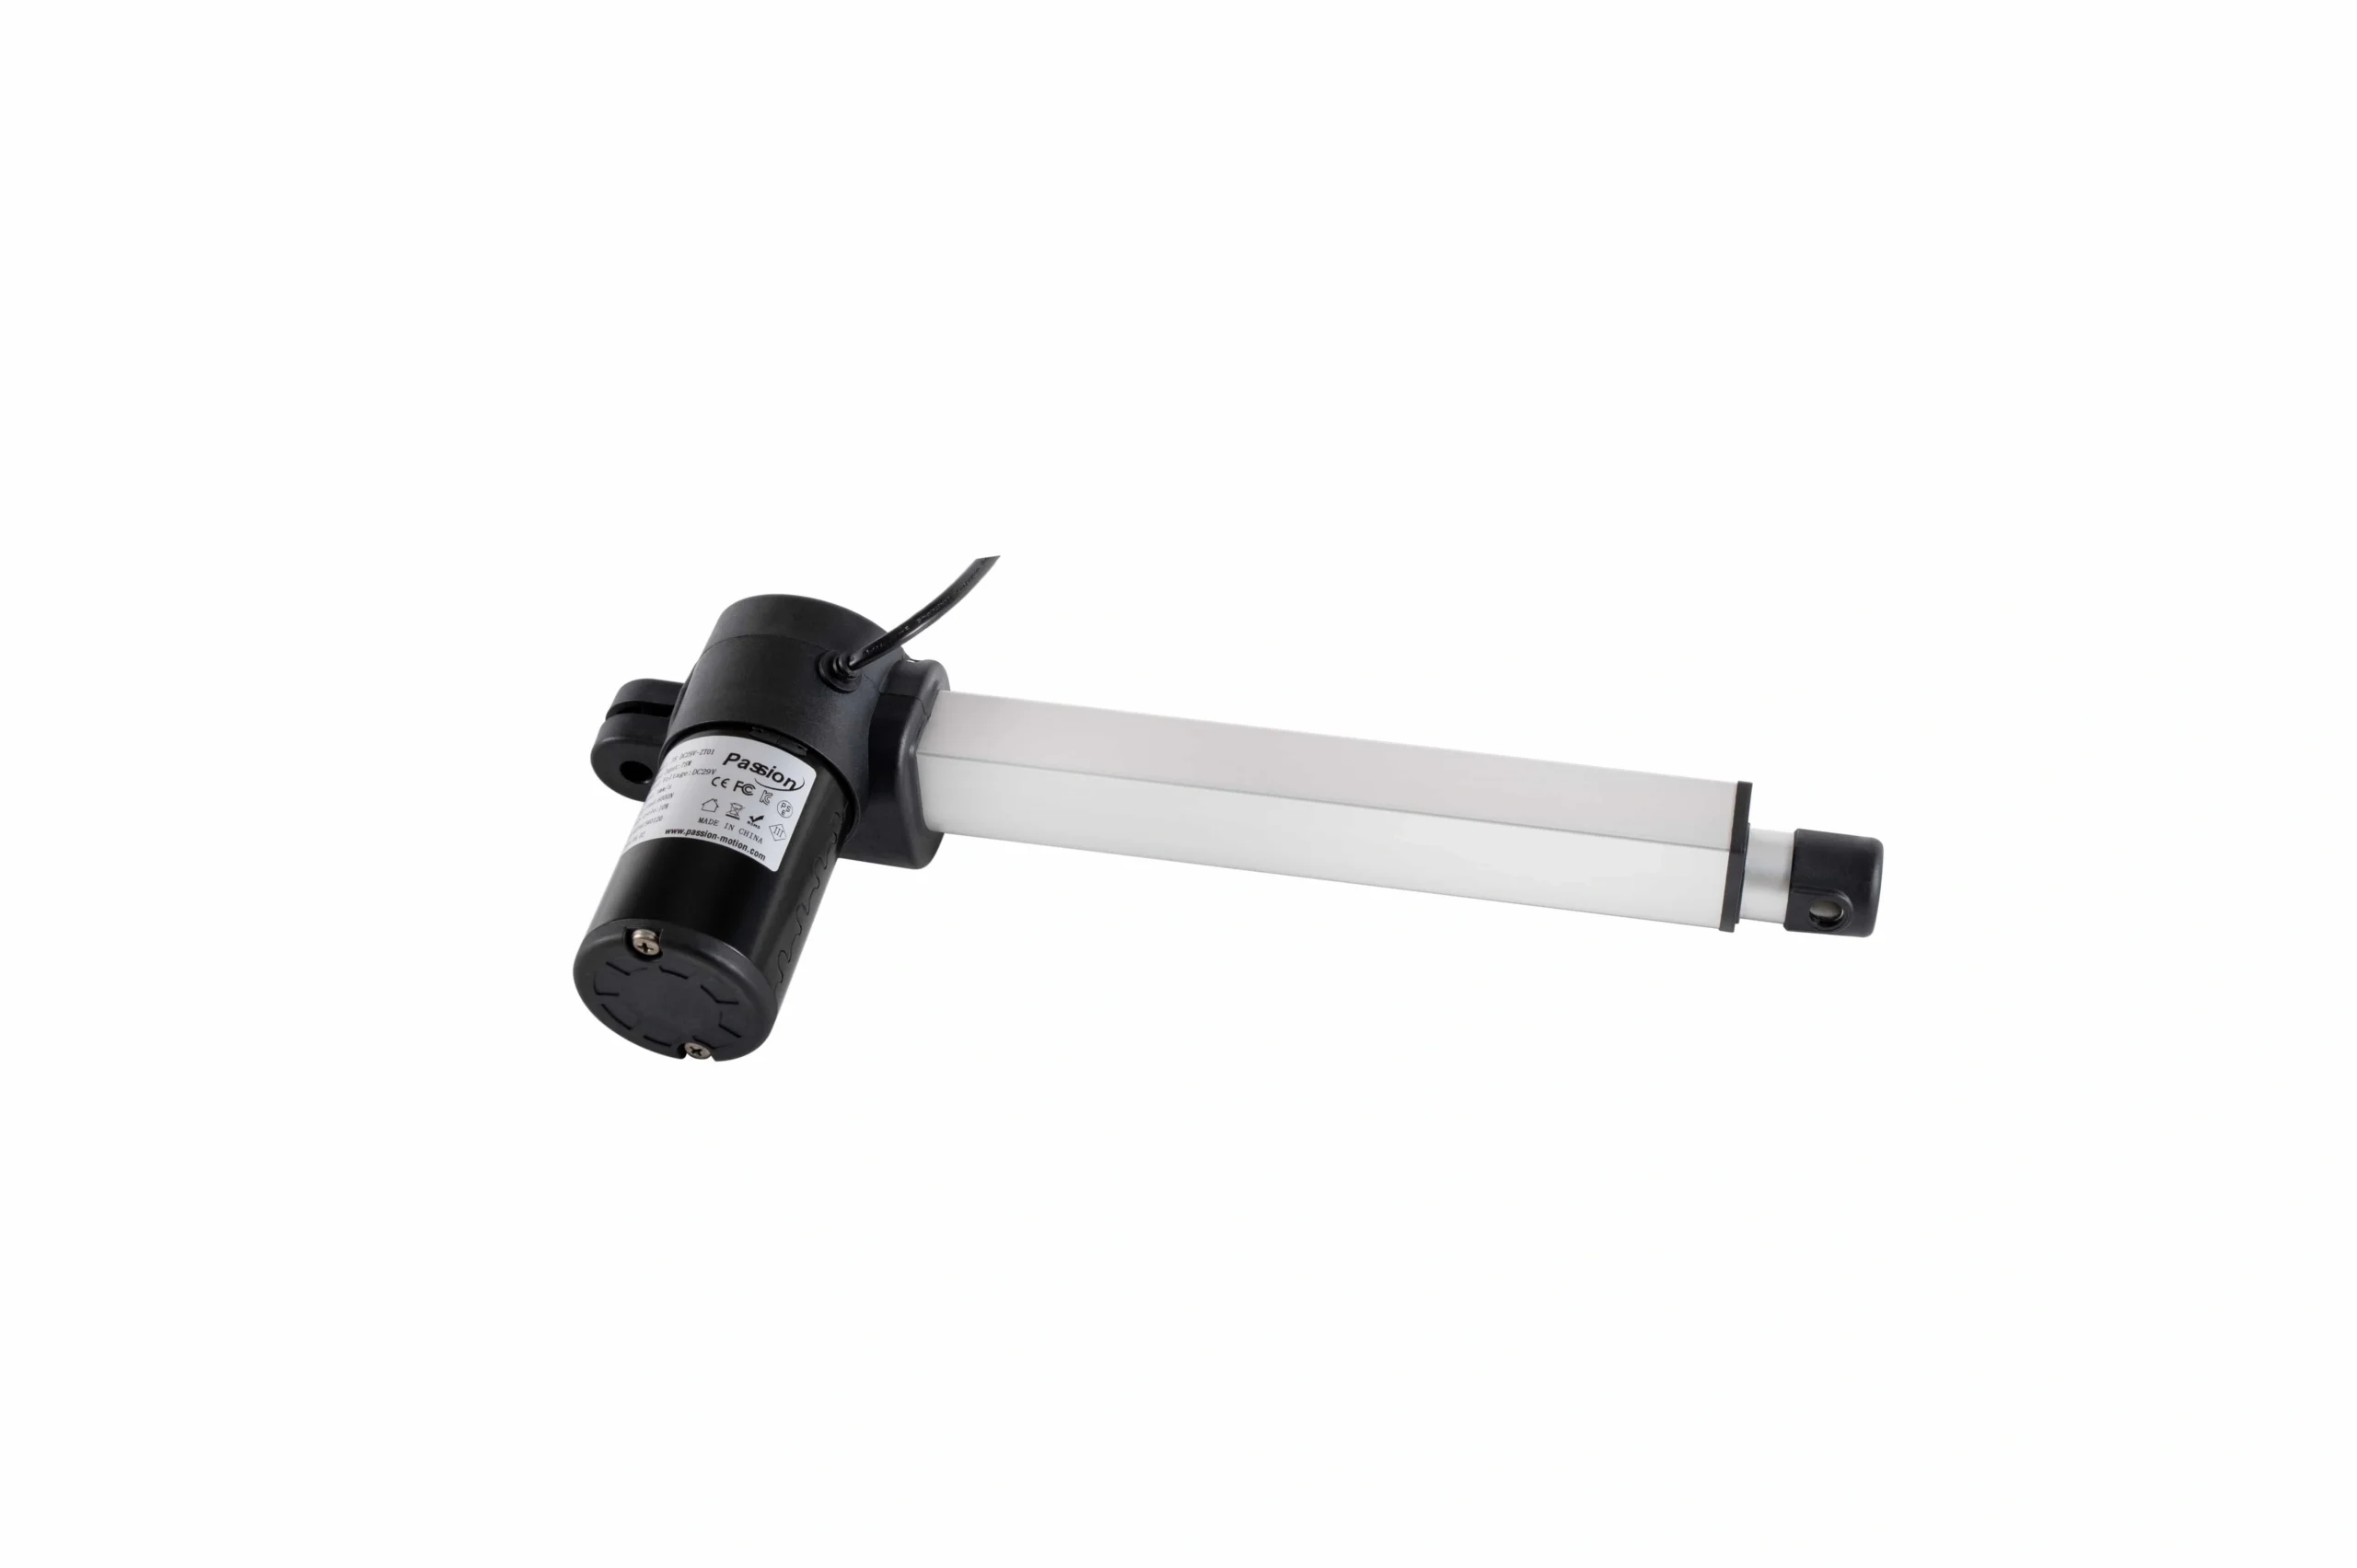
パッケージ型ロッドユニットは、モーター、ギヤボックス、チューブ、およびエンドマウントをコンパクトなアセンブリに組み合わせています。
実際のアプリケーションのための意思決定マトリックス
| 要件 | サーボねじシリンダーを選好する場合… | パッケージ型DCユニットを選好する場合… | 選択する前に確認してください |
|---|---|---|---|
| モーションタスク | 軸には複数の位置が必要であり、制御された加速、レシピ変更、または他の軸との調整が必要です | タスクは主に伸縮、上下、または時折の再配置です | 位置カウント、移動プロファイル、ホーミング、同期 |
| 力の振る舞い | 力関連の制御または監視はプロセスの一部であり、感知方法は定義されています | ユニットは既知の負荷エンベロープ内でのみ移動する必要があります | 定格とピークの力、負荷速度曲線、センサーの位置 |
| サイクルレート | 完全にサイズ調整されたモーター/ねじ/熱システムが指定された生産サイクルをサポートします | 文書化された間欠定格が運転-休止パターンに適合します | 負荷、速度、作動時間、休止時間、サイクル/時間、周囲温度 |
| 電源オフ状態 | 軸には評価されたブレーキまたは独立した保持方法が設計されています | 文書化されたセルフロックまたはブレーキ装備モデルは、保持要件を満たします | バックドライブ負荷、静的保持定格、ブレーキトルク、故障応答 |
| 位置性能 | 発表されたシステムの精度と繰り返し精度はプロセスの公差に合致しています | モデル特有のフィードバックとコントローラーの性能は十分です | 精度、繰り返し精度、分解能、バックラッシュ、負荷および温度条件 |
| 側面またはモーメント負荷 | 機械は外部ガイドまたは評価されたガイド構成を提供します | メカニズムはヒンジ、レール、またはベアリングを通じて側面負荷を負担します | 半径/モーメント定格、全ストローク整列、ブラケットの自由度 |
| コントロール | 機械はすでに互換性のあるサーボプラットフォームを使用しているか、診断およびネットワーク化された運動が必要です | スイッチ、リレー、Hブリッジ、またはコンパクトコントローラーがタスクを完了します | 電圧、電流、ドライブ、フィードバック、コネクタ、フィールドバス |
| 商業ケース | 制御能力、サイクル性能、診断、または切り替え値が全軸を正当化します | シンプルなメカニクスとコントロールが完全なインストールを経済的に保ちます | アクチュエータ、ドライブ、コントローラ、ケーブル、センサー、ガード、セットアップ、スペア |
「より良い」オプションは、必要な動作点で各行を閉じるものです。適切なフィードバックと定格を持つシンプルなユニットは、意図されたタスクにおいて過小サイズのサーボ軸を上回ることができます。正しくサイズ設定されたサーボ軸は、余分なスイッチ、ストップ、または手動調整を必要とする運動機能を提供できます。
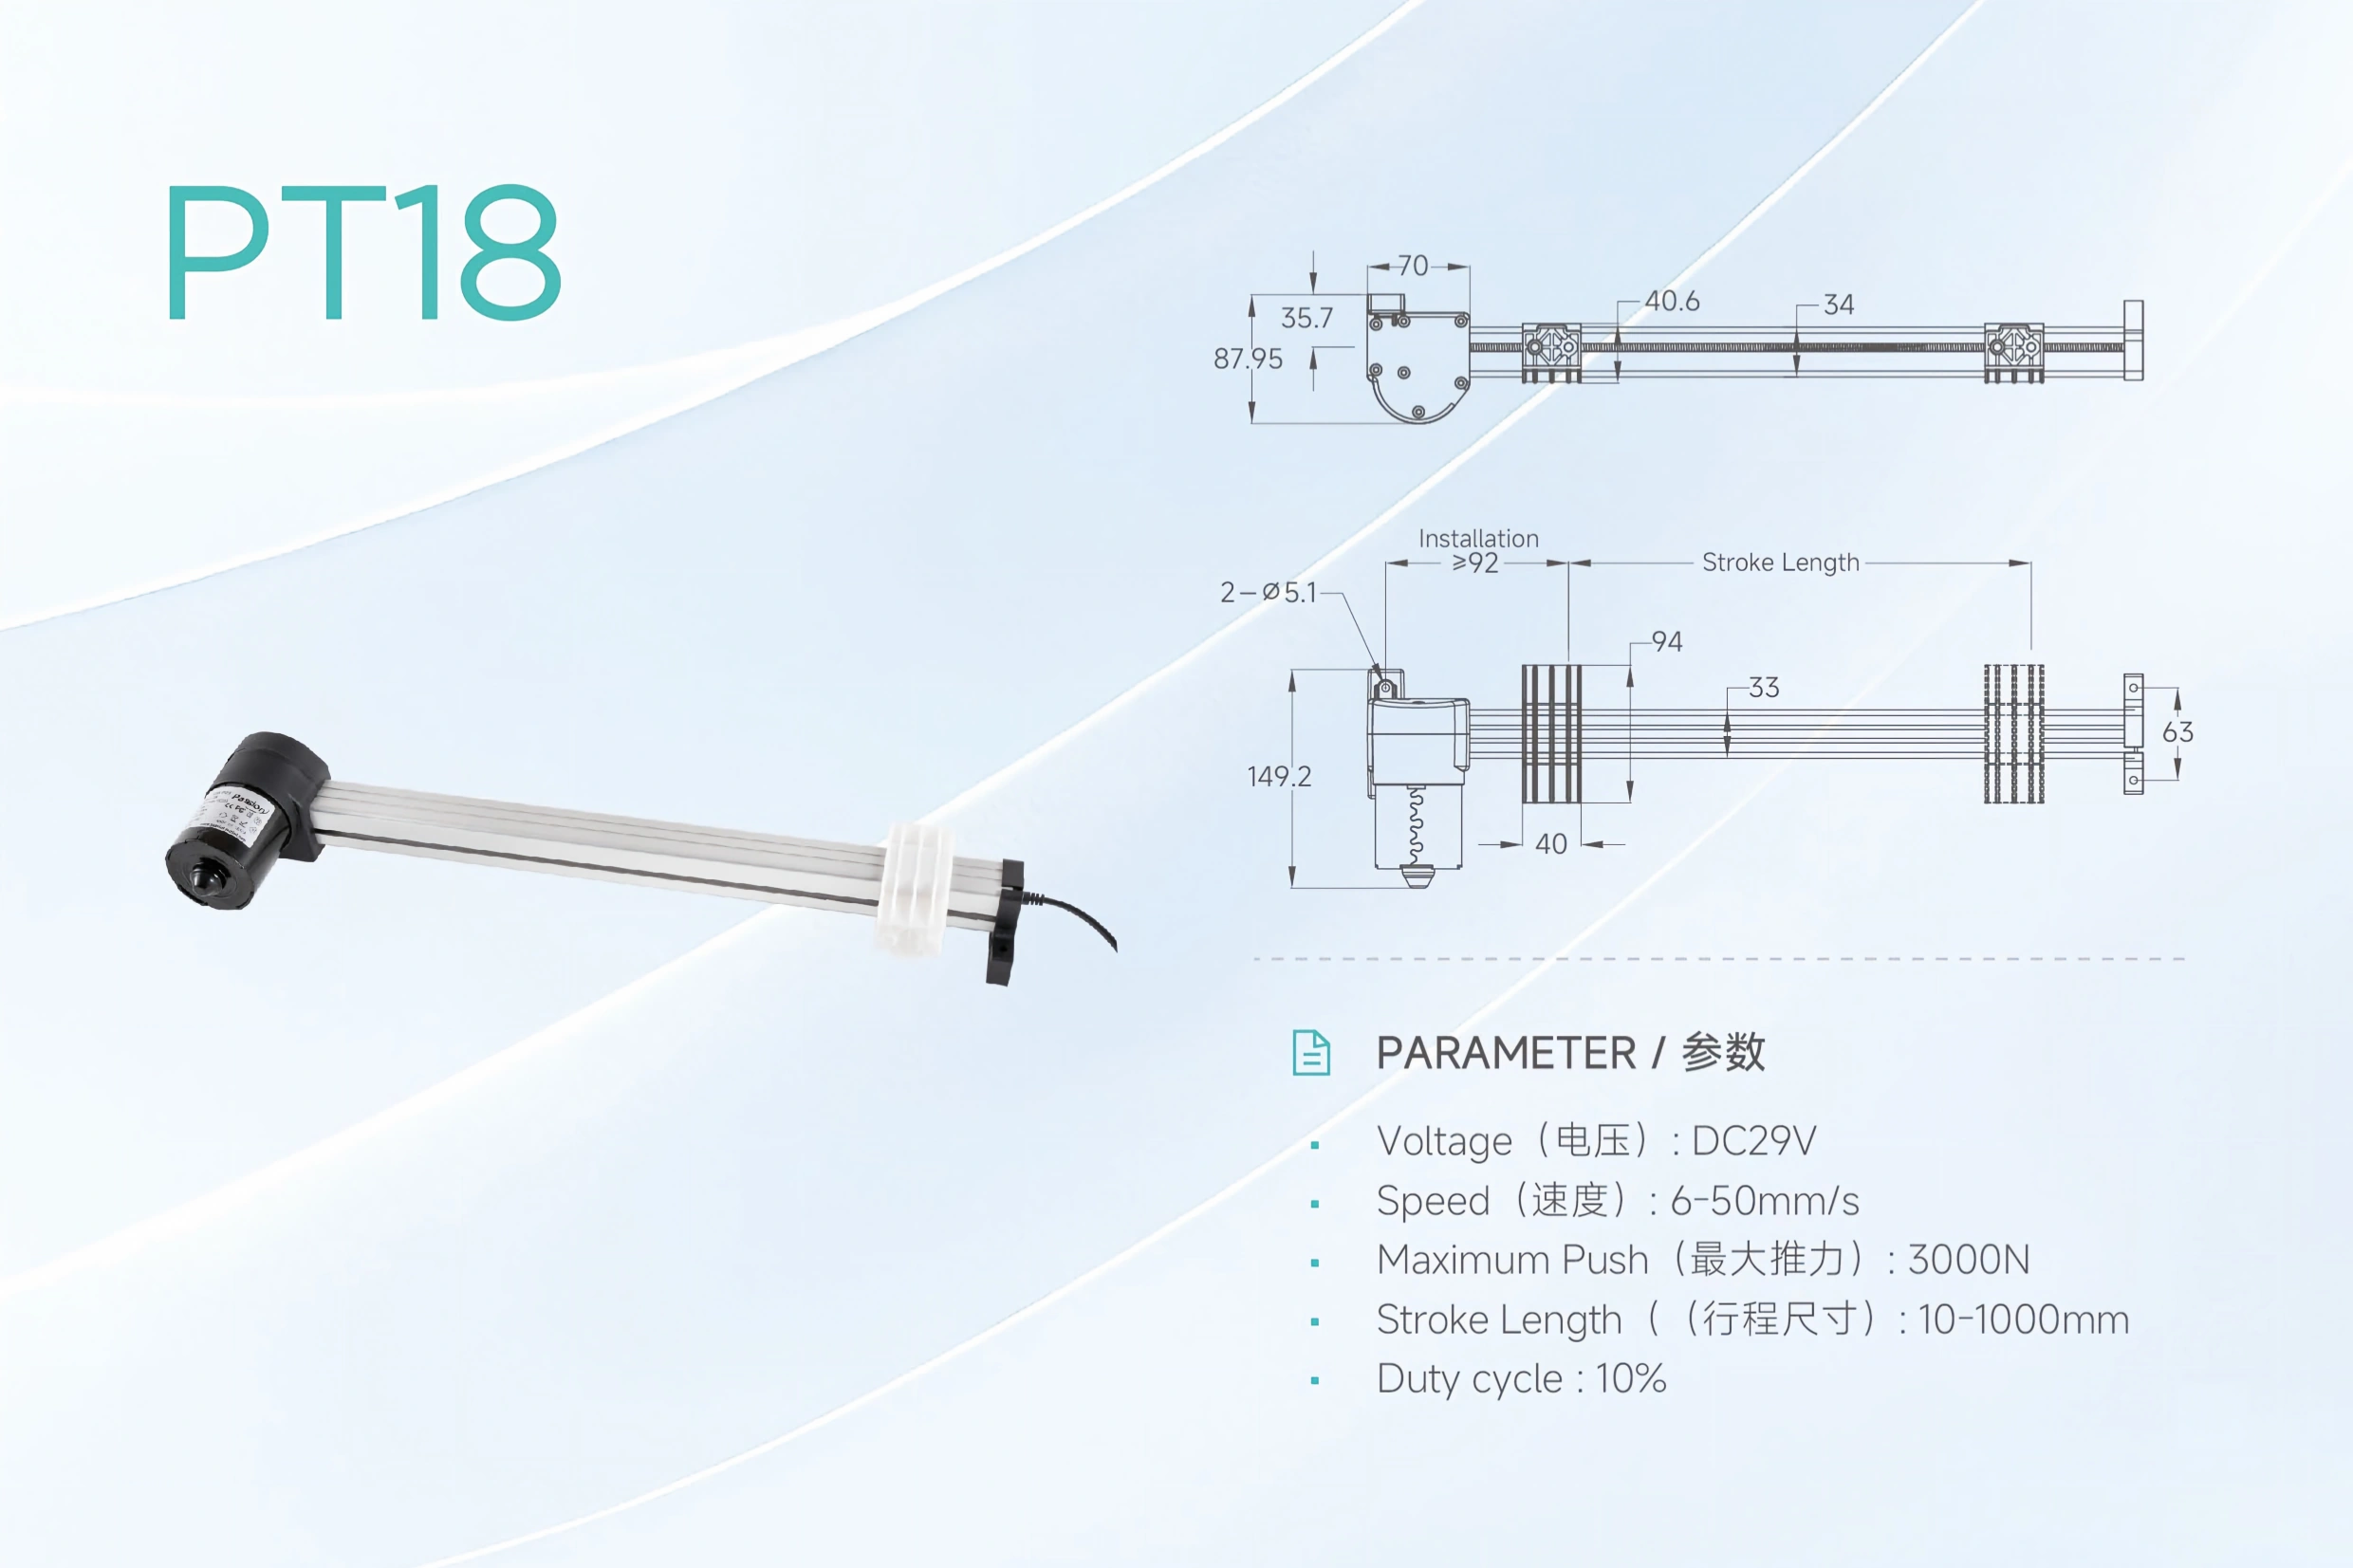
PT18スライダーのレイアウトは、広範なカテゴリが1つのシリンダー型フォームに縮小できない理由を示しています。
すべての仕様を操作点として読む
力、速度、ストローク、そしてデューティサイクルは相互に関連しています。大きなスクリューリードは、回転あたりの直線移動量を増加させる一方で、機械的アドバンテージを低下させることがあります。より多くの減速は、スピードを下げながら利用可能な推力を増加させることができます。より長いスクリューは、バッキングやクリティカルスピードの限界を引き起こす可能性があります。より高い負荷と長いオンタイムは、モーター、ドライブ、ベアリング、スクリュー、およびグリース内の熱を増加させます。
そのため、別々の範囲フィールドからコピーされた4つの番号は、1つの使用可能な構成を示しません。必要なストローク、方向、加速度、サイクル、および周囲条件の下で、正確なモデルの力-速度曲線またはサイズ結果を求めてください。
ServoCylMotionの文書化された例は、アーキテクチャの範囲とラベルベースの仮定の限界を示しています:
| 例 | 記録された力フィールド | ストローク | 記録された速度 | その他の制御データ | 示すこと |
|---|---|---|---|---|---|
| DG52-50KG-190-5 | 定格出力:約490 N | 190 mm | 定格:125 mm/s | 5 mm ボールスクリュー、0.4 kW サーボ、折り返しモーター | サーボスクリューシリンダーは、軽負荷の高速度ポイント向けに構成できます。 |
| DG95-1.5T-250-5Z | 定格推力:15 kN | 250 mm | 定格:83.3 mm/s | 5 mm ボールスクリュー、1.5 kW サーボ、1:2 減速 | 大きなサーボ構成は、異なるモーターと減速と組み合わせて、より高い定格推力を提供します。 |
| ZT01 | 最大押し圧力:6000 N | 10–600 mm のオプション | 6–40 mm/s のリスト範囲 | DC 29 V、10% デューティサイクル | パッケージ化されたロッドユニットは、軽量DGの例よりも高いヘッドライン力を運ぶことができます。 |
| PT18 | 最大押し圧力:3000 N | 10–1000 mm のオプション | 6–50 mm/s のリスト範囲 | DC 29 V、10% デューティサイクル、スライダー幾何学 | 広範なファミリーには、シリンダースタイルのロッドレイアウトなしでのキャリッジモーションも含まれています。 |
DG値は定格フィールドですが、ZT01およびPT18値は最大/範囲フィールドです。それらは同等の試験条件ではなく、直接比較すべきではありません。実際の教訓は、製品名は力の階層を創出しないことです。
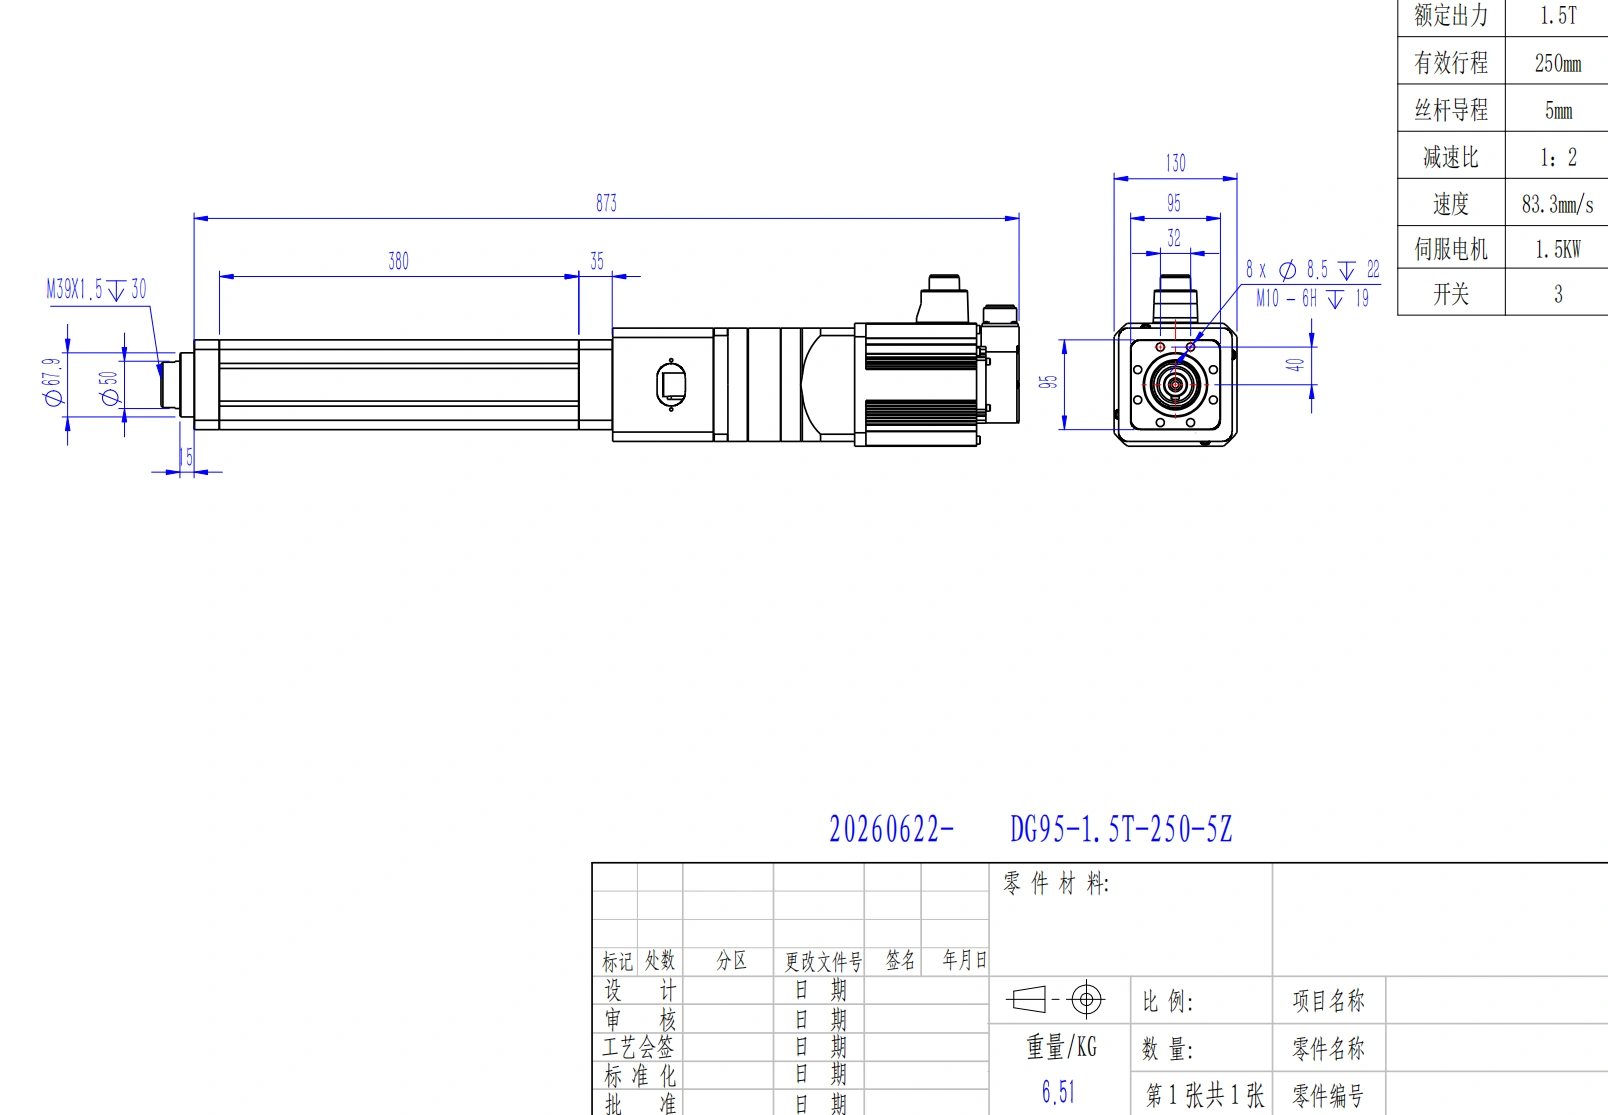
フルインストールエンベロープとマウントインターフェースをチェックするには、制御モデル図が必要です。
最も一般的な比較エラーを防ぐための5つのチェック
1. Separate Position Feedback From Force Measurement
An encoder, resolver, Hall sensor, or potentiometer reports motion at a particular point in the system. It can support position control, speed control, and synchronization. It does not automatically measure the force at the workpiece.
Servo torque or motor current can provide a useful force estimate, but friction, acceleration, screw efficiency, belt tension, structural compliance, and temperature affect the result. If process force is a quality or safety variable, specify a calibrated load cell or force sensor and define where it is installed.
2. Define the Power-Off State
For a vertical or overhauling load, state what must happen after a power loss. A ball-screw axis may backdrive. A lead screw or gearbox may resist backdriving, but that behavior must be documented for the exact load and wear condition. A holding brake also needs a rated torque, control sequence, and failure analysis.
Do not use motor torque at zero speed as the only retention method. Where uncontrolled motion can injure a person or damage equipment, add appropriate mechanical support and a machine-level safety review.
3. Keep Side Loads Out of the Rod
A thrust rating describes axial work. Offset forces and moments can load the extension tube, nut, screw, seals, bearings, and gearbox. Use external rails, bearings, hinges, spherical joints, or a rated guided configuration to carry those loads. Check alignment through the entire stroke, not only at the retracted position.
The PT18 image above also shows why form factor matters: a moving carriage and a thrust rod create different load paths and mounting interfaces even when both produce linear motion.
4. Convert “Duty Cycle” Into a Motion Schedule
A percentage alone is incomplete. Define move time, dwell time, rest time, cycles per hour, load during each phase, acceleration, ambient temperature, and expected service life. Servo components can also overheat when the screw, motor, brake, or enclosure is undersized. A servo label is not a continuous-duty rating.
For the documented DG products, ServoCylMotion’s maintenance guidance calls for initial grease replenishment after 300 operating hours and subsequent replenishment every 2000 hours. It also calls for several unloaded low-speed cycles after greasing and timing-belt inspection on return-type layouts. Apply these instructions only to the products covered by that guidance.
5. Compare the Installed System
A component-price comparison can omit the parts that determine the project cost. Include the motor, drive, controller, power supply, cables, connectors, sensors, brake, mounting hardware, external guides, control enclosure, guarding, programming, commissioning, spare strategy, and maintenance access.
An integrated servo design may remove motor-mount hardware. A packaged unit may reduce wiring for a basic endpoint task. Either advantage can disappear when the application needs added feedback, synchronization, safety functions, or custom integration.
When Each Approach Usually Fits
A servo screw cylinder is usually the better starting point when the machine needs:
- repeatable intermediate positions or motion profiles;
- coordinated multi-axis motion;
- 制御された加速と減速;
- process recipes or rapid changeover;
- motion diagnostics and industrial network integration;
- a defined force-related process with the correct sensing architecture;
- a motor, drive, and screw sized together for the production cycle.
A packaged DC rod or slider unit is usually the better starting point when the mechanism needs:
- simple extension and retraction;
- intermittent lifting, opening, tilting, or adjustment;
- endpoint control or modest position feedback;
- a compact, self-contained mechanical package;
- straightforward replacement as a complete unit;
- documented load, speed, duty, environment, and holding performance without a full servo platform.
For compact endpoint and slider architectures, review the available rod and carriage families against the same operating-point checklist.
RFQに含めるべき内容
A useful request identifies the application before asking for a model:
- 負荷: moving, static, shock, friction, and worst-case linkage force in both directions.
- 動作: stroke, loaded speed, acceleration, deceleration, move time, and required positions.
- Cycle: moves per hour, on-time, dwell, rest, shifts per day, and ambient temperature.
- ジオメトリ: retracted and extended length, mounting points, orientation, collision envelope, and external guidance.
- Performance: accuracy, repeatability, resolution, backlash, and acceptable deflection.
- 制御: supply voltage, servo platform or controller, feedback type, I/O, fieldbus, synchronization, and cable requirements.
- Force and holding: whether force is estimated or measured, sensor location, power-off state, brake, and independent load support.
- Environment and service: dust/water exposure, temperature, contamination, lubrication access, expected life, and replacement strategy.
If the load changes through a linkage, calculate the required operating point across the full travel before comparing model tables.
よくある質問
Are an electric cylinder and a linear actuator the same thing?
The first is generally one implementation of the second. Vendor names overlap, so confirm the motor, transmission, output form, feedback, ratings, and control interface instead of classifying a product by its name alone.
Is a servo screw cylinder always more powerful?
No. Available force depends on the motor, drive, screw type and diameter, lead, gearing, stroke, bearings, thermal limits, and rating definition. Compare rated or continuous performance at the required speed and cycle.
Can a packaged DC unit stop at intermediate positions?
Yes, if the selected model provides suitable position feedback and works with a controller that closes the position loop. End switches alone only establish travel endpoints.
Does a servo encoder provide force feedback?
An encoder provides position or motion feedback. A drive may estimate force from motor torque or current, but measured workpiece force normally requires a documented force sensor or load cell and a defined calibration method.
Which option will hold a vertical load without power?
Either may hold if the exact configuration has sufficient self-locking behavior, a correctly sized brake, or another rated retention method. Neither category guarantees it. Specify the static holding load, backdrive condition, brake behavior, and failure response.
Is a servo cylinder suitable for continuous operation?
Only when the complete motor, drive, screw, bearings, lubrication, cooling, and motion profile have a continuous rating under the stated load and temperature. The servo control method alone does not establish duty capability.
What is the most important comparison document?
Use the exact model data sheet, force-speed or sizing output, dimensional drawing, control/feedback specification, and maintenance instructions together. No single headline specification describes the installed axis.
Move From Comparison to a Checked Configuration
Bring the load profile, stroke, loaded speed, cycle schedule, installation envelope, control method, and power-off holding requirement. Then review ServoCylMotion’s cylinder-family configurations against one complete operating point.










